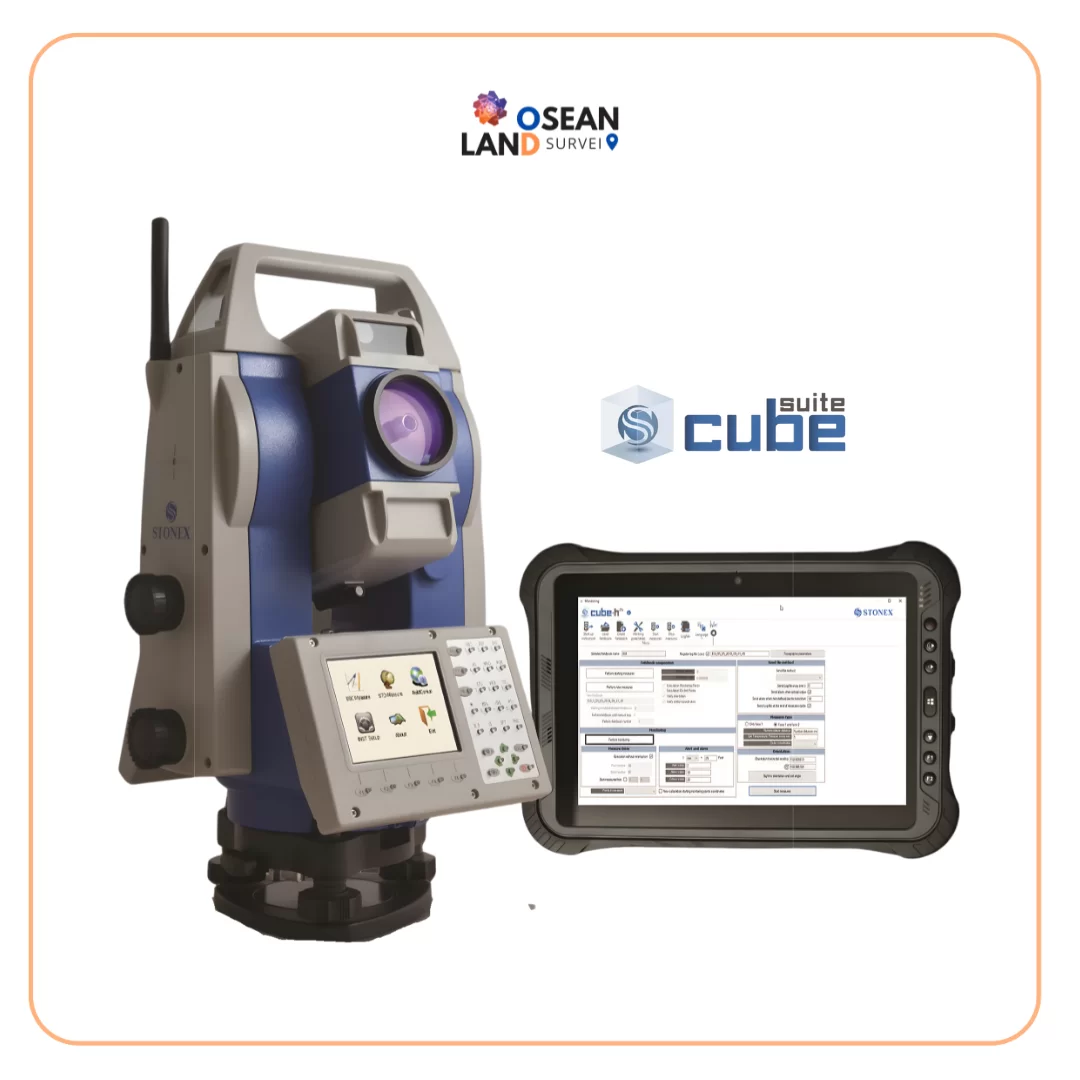
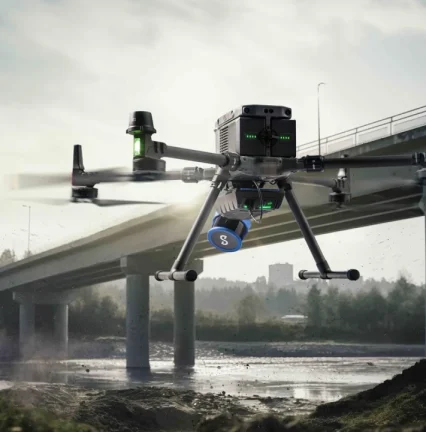
The software performs a multi-constellation (GPS, GLONASS, Beidou, Galileo) and multichannel (L1, L2, L5) GNSS post processing PPK of Base-Rover configurations. Such configurations can be found in many UAV / drone applications and terrestrial 3D ImageVector devic. The corrected GNSS path accuracy is at centimeter level. Depending on the device use, the current satellite constellation and receipt quality.
Outputted as plain Text, as image EXIF data or in native Agisoft, Pix4d and Google Earth files, this information can be used in many other fields of applications., eg. in photogrammetry and documentation.
Compatible to many drones and devices, such as:
DJITM P4RTK Phanton4 RTK
DJITM M300 P1 camera, L1 (RGB camera)
DJITM MAVIC 3 Enterprise RTK ***** NEW *****
AutelTM EVO2 RTK
YuneekTM H520 RTK
ubloxTM ZED F9P, M8P chips
ubloxTM kits like: TopoDrone, Teokit, metta, etc
3D ImageVector – camera GNSS & IMU
SepentrioTM mosaik drone kits
SwiftnavTM – Piksi kits
EmlidTM Reach kits